Process Overview
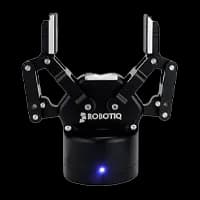
This deployment is an automation solution for part assembly and processing lines using an All Picker Gripper. As the name suggests, the All Picker Gripper is designed to pick a wide range of objects, and it can perform stable picking even when the workpiece has holes or an irregular shape.
구성요소
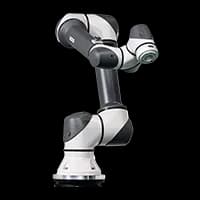
| 로봇 | Robot + gripper All Picker Gripper Payload: 10 kg Size can be customized to match the workpiece requirements |
|---|---|
| 주변기기 | Conveyor |
작업순서
| STEP 1. | Part loading |
|---|---|
| STEP 2. | Conveyor and lift operation |
| STEP 3. | Empty-box outfeed via conveyor |
| STEP 4. | UR robot and hand chuck operation |
| STEP 5. | Cylinder alignment (part positioning) |
| STEP 6. | Mold part loading (after completion, pin-up) |
| STEP 7. | Finished-product outfeed via conveyor. |
※ 마로솔 내의 모든 콘텐츠를 무단으로 복사 및 재창작할 경우 부정경쟁방지법 및 저작권법에 위반될 수 있음을 밝힙니다.
추천 도입사례

Box Pick-and-Place Automation Solution Using a Box Picker Gripper
Process Overview This deployment is a box pick-and-place automation solution using a Box Picker Gripper. As the name suggests, the Box Picker Gripper is designed to pick a wide range of objects. In this solution, it enables stable picking even when plastic boxes are open-top (without lids), improving handling reliability in box transfer operations.

afwefawe
awef

260706 en_test
This application is an order picking system that optimizes the operation of 10 Eugene Gocart 180 vehicles using the Marosol remote control system SOLlink.
Process Overview
This deployment is an automation solution for part assembly and processing lines using an All Picker Gripper. As the name suggests, the All Picker Gripper is designed to pick a wide range of objects, and it can perform stable picking even when the workpiece has holes or an irregular shape.
구성요소
| 로봇 | Robot + gripper All Picker Gripper Payload: 10 kg Size can be customized to match the workpiece requirements |
|---|---|
| 주변기기 | Conveyor |
작업순서
| STEP 1. | Part loading |
|---|---|
| STEP 2. | Conveyor and lift operation |
| STEP 3. | Empty-box outfeed via conveyor |
| STEP 4. | UR robot and hand chuck operation |
| STEP 5. | Cylinder alignment (part positioning) |
| STEP 6. | Mold part loading (after completion, pin-up) |
| STEP 7. | Finished-product outfeed via conveyor. |
※ 마로솔 내의 모든 콘텐츠를 무단으로 복사 및 재창작할 경우 부정경쟁방지법 및 저작권법에 위반될 수 있음을 밝힙니다.